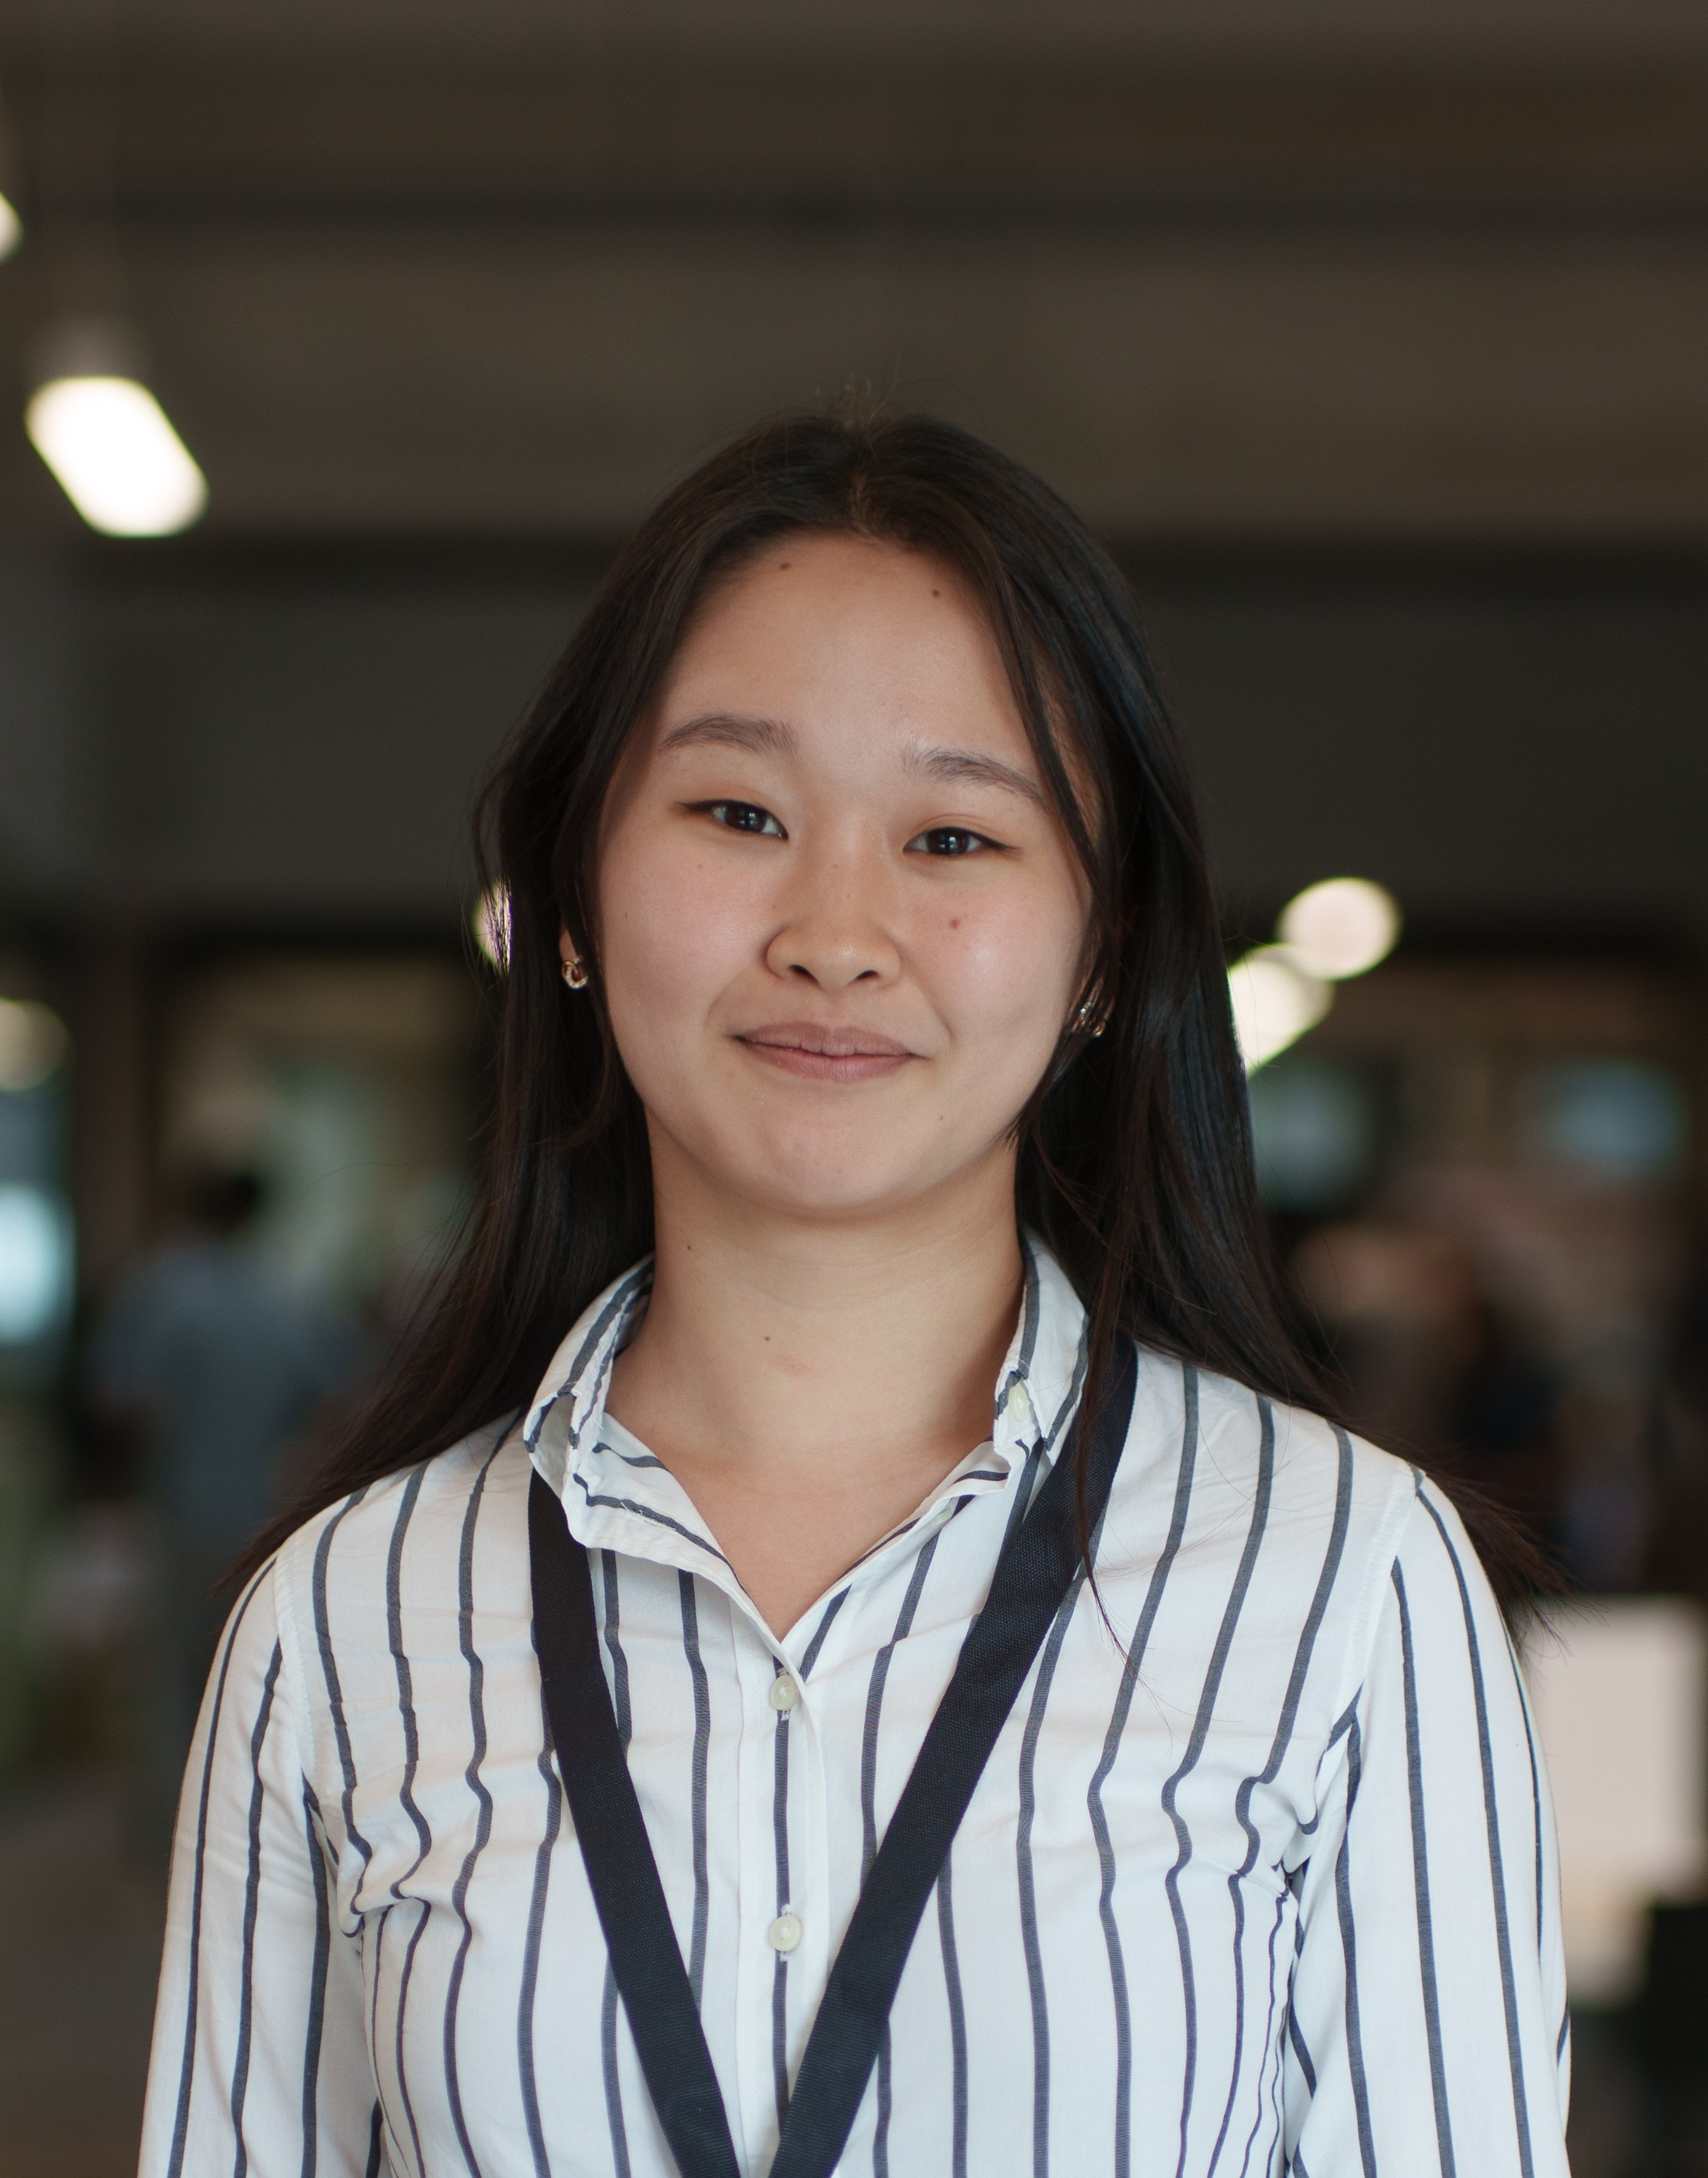
Hi there!
My name is Yume Yamamoto, and I’m in my fourth year of Robotics Engineering at Engineering Science, University of Toronto.
I have 8+ years of experience in robotics and 3+ years of technical leadership, working with automotive, aerospace, mobile robots, manufacturing, and embedded systems.
Some things I enjoy as an engineer:
•Developing software for physical systems
•Testing and seeing robots work (or break)
•Working in teams
•System integration and deployment
•Preparing robots for a real, uncertain world
Curious what I've been building? Take a look at my projects page.
Feel free to contact me through LinkedIn or email (yume.yamamoto[at]mail.utoronto.ca).
ROS1/2 Python C++ C RPi/ESP32/Arduino Computer Vision SLAM Gazebo/Isaac Sim UAV AV Guidance/Navigation Controls
Recent Work & Research Experience
Autonomous Vehicle - Software Safety Intern
General Motors · May 2026 - Aug 2026
Computer Vision Software Co-op
Martinrea International Inc. · May 2025 – Apr 2026
Thesis Student
Toronto Robotics and AI Lab (TRAIL) · 2025 – Present
Education
Bachelor of Applied Science (BASc) in Engineering Science
University of Toronto · 2022 – 2027
Robotics Engineering Major • Artificial Intelligence Minor
Awards
2022–25 Dean's Honours List
2023 Engineering Science Research Opportunity Program (ESROP) – Global
2024 First Place — Engineering Case Competition by Qualcomm
2023 Make U of T Hackathon — Qualcomm Sponsored Prize, Best Innovative Use of Qualcomm HDK8450
2022 Dean's Merit Award — Entrance Scholarship
2022 Schulich Leader Scholarship Finalist
2022 FIRST Robotics Dean's List Semi-finalist
Certificates
Certified SOLIDWORKS Associate in Mechanical Design (CSWA)
Fundamentals of Machining — George Brown College
Small Remotely Piloted Aircraft (VLOS) Basic Operations — Transport Canada
Working at Heights +
Mobile Elevated Working Platform
Relevant Courses
Dynamics Control Theory Computer Vision Linear Algebra Digital/Analog Circuits Operating Systems Embedded Systems Machine Learning Deep Learning Data Structures & Algorithms Robot Kinematics